Soft Gripper End Effector Mar 11 Written by Julie Le For my senior design project, we worked to simulate our CHEF: Autonomous cooking robot in ROS. I designed and prototyped a soft silicone gripper to be used with soft and delicate foods. The gripper is actuated through pneumatic air pressure. Julie Le Previous Previous 3D User Interaction Device for Augmented Reality Applications Next Next Simulating Manipulators with Robotic’s Toolbox
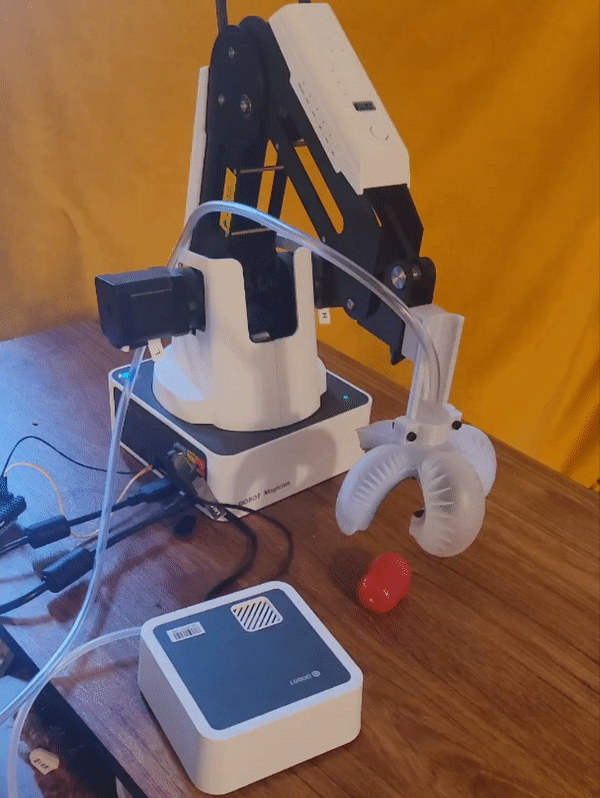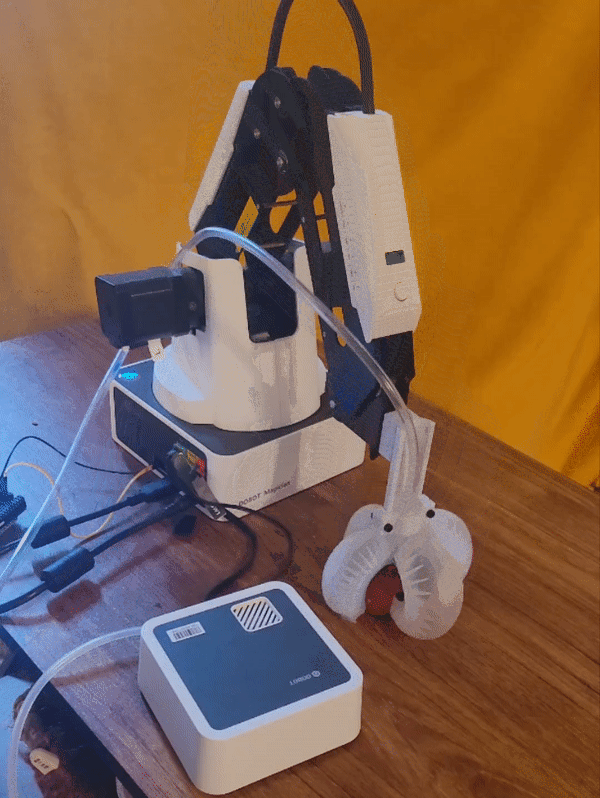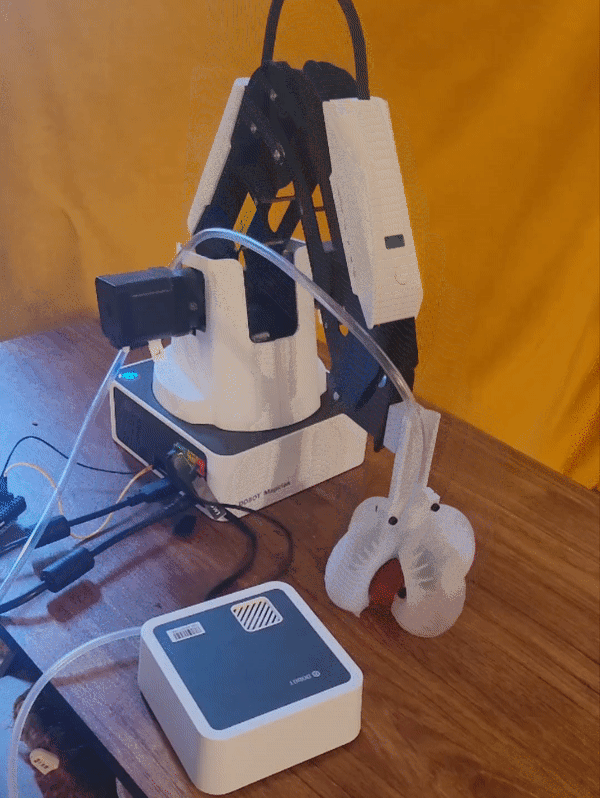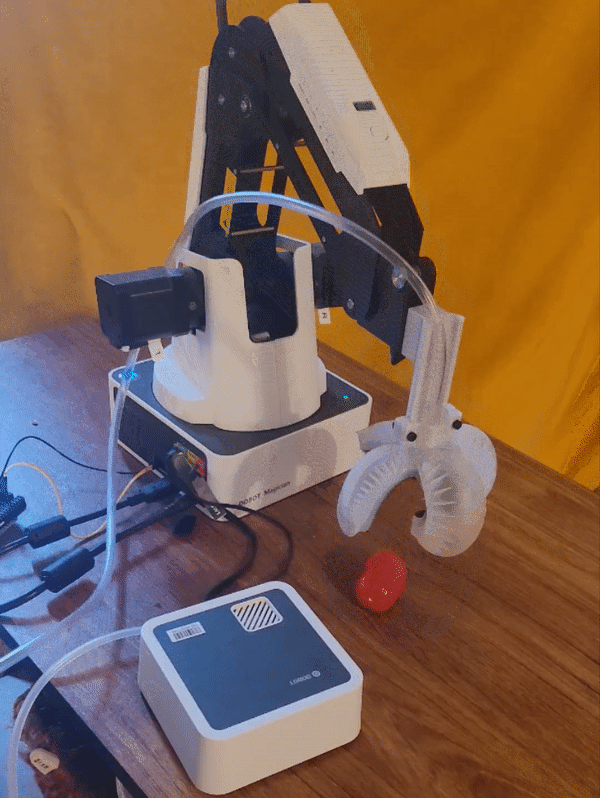
Soft Gripper End Effector Mar 11 Written by Julie Le For my senior design project, we worked to simulate our CHEF: Autonomous cooking robot in ROS. I designed and prototyped a soft silicone gripper to be used with soft and delicate foods. The gripper is actuated through pneumatic air pressure. Julie Le